 Korkut Kaynardag
Laser Doppler Vibrometer (how it works, advantages and disadvantages, speckle noise)
The video below shows very clearly how LDV works. Then, I explain (i) further how LDV works, (ii) LDV applications' advantages and disadvantages, and (iii) how speckle noise occur in LDV measurements. I use 8 publications for these explanations and refer you to these papers for more information.
Note: I am adding 3 papers to the end of this section. Even though the main goal of these papers was to examine the level of speckle noise, they provided information about the factors causing of the speckle noise occurrence as well. Therefore, they are nice compliments to the first 8 papers.
Main information about LDV:
An LDV measures the vibrations of a structure by sending a coherent light beam incidentally on a target surface and then observing the changes in the phase or frequency of the backscattered light relative to the transmitted light (i.e., Doppler signal) [1–3]. These changes occur due to out-of-plane vibrations of the target surface (Doppler effect). The displacement of the vibration is obtained upon phase demodulation while velocity is obtained through frequency demodulation or differentiation of displacement. However, when the coherent laser beam scatters from a surface whose roughness is comparable to the optical wavelength in the out-of-plane direction, a random distribution of high and low-intensity light patterns (i.e. a speckle pattern) occurs. This is a result of the reflection from dark and light surface spots. Such low-intensity regions adversely affect signal intensity. However, since the distance between the surface points and the LDV is different, the phases of the speckle pattern can be different as well. As long as the transmitted and backscattered lights are coaxial, phases of the speckle pattern are still converted into a homogenous phase shift, leading to the vibrations of the target surface. However, if the target surface undergoes in-plane motions, the speckle pattern changes dynamically, leading to random phase changes as well as intensity modulations. Phase distribution might integrate up to an erroneous phase contribution (i.e., phase modulation), when modulated, resulting in a displacement offset causing dropouts in the recorded voltage [4]. Such dropouts can also occur as a result of the movement of the laser beam over dark spots as a result of low-intensity light causing lower doppler signal amplitude (i.e., amplitude modulation). Generally, the Doppler signal’s large phase changes and low amplitude occur at the same time, but large phase changes may occur even though the doppler signal amplitude is adequate. The dropouts cause spikes in the vibration signals which also result in broadband noise in the frequency domain. Even in the absence of spikes in signals, the noise level in the frequency domain can still increase as a result of random phases of the backscattered light.
I compiled 8 papers to read to learn about (i) how an LDV works in detail, (ii) the applications of LDV technology, (iii) the advantages and disadvantages of LDV technology (i.e., the uncertainties and problematic factors), and (iv) how the noise in LDV measurements occur and how this noise is modeled analytically and numerically:
[1] and [2] are good papers that give information about how an LDV works (without getting into rigorous formulations), the application fields of LDV technology, and the limitations as well as the innovative solutions of LDV applications.
[3] is a good paper to start understanding how LDVs work (more in detail explanation). The paper first explains the internal components of LDVs, and then talks about shot noise and thermal noise (which are actually not considered when speckle noise exists in LDVs since their contributions are negligible compared to speckle noise). Afterward, the paper explains how target structures’ vibrations cause phase modulation in the LDV’s doppler signal, as well as how this phase modulation yields to frequency demodulation of the doppler signal which is a function of the target structures’ vibration velocities. Therefore, the paper shows that phase modulation has information about the displacements while frequency modulation has information about the velocities of the target structures. Then, the paper explains how analog velocity decoders recover the vibration
information in terms of velocity using the frequency modulated signal while how analog displacement decoders obtain the vibration information in terms of displacement. Afterward, the paper talks about digital decoders to overcome the limitations of analog converters. These digital converters use methods like fringe counting and arctangent phase modulation (I/Q) both of which give the phase of the doppler signal. In these methods, velocity information is obtained by integrating the phase information. Note: I do not know exactly what kind of decoders are used in LDV controllers. For example, in the datasheet of a Polytec brand LDV controller, several different decoders are listed for velocity and displacement. Some of these decoders are called I/Q decoding, analog displacement, analog velocity, digital velocity, and digital displacement.
An early study [5] analyzes the speckle noise in LDV signals using the theory of frequency demodulation since this is how LDVs convert the frequency and phase-modulated backscattered (or reflected) laser beam into vibration signals. First, the paper formulates the autocorrelation function of the phase derivative since the power spectrum of the demodulator can be obtained using this function. Next, the correlation function required in the autocorrelation is formulated. The correlation function and spectral power density are plotted in terms of the bandwidth of the speckle noise (i.e., time taken for speckle pattern to advance one speckle). Then, the paper also considers additive noise to improve the accuracy of the results where the speckle-noise intensity, the additive noise intensity, the speckle-noise bandwidth, the additive noise bandwidth, and the baseband filter width come into play as well. Plots of the noise in terms of the mentioned parameters were presented in the paper. Afterward, the results were compared with a corrected form of formulation of the noise power presented in the literature on frequency demodulation, and consistent results were obtained. However, both the developed formulation of LDV noise which includes additive noise, and the corrected form of the formulation taken from the literature requires the information about mentioned parameters.
In [4], first, it is presented again how vibrations of a target structure in terms of displacement change the phase information of the doppler signal, and how velocity information can be obtained by (i) the temporal derivation of this signal, (ii) or direct frequency demodulation of the doppler signal since phase modulation also causes frequency modulation as mentioned in [3]. Then, it gives information about how speckles (mentioned in the first paragraph of this document) are formulated and explains how an arbitrary changing phase map (as a result of the movement of the LDV over the target structure) causes arbitrary phase jumps in the doppler signal of LDV, causing more noise in the measurements. The paper uses examples from a simulation where it is shown that (i) when the doppler signal has low intensity (less reflected light from the surface), phases are high, and (ii) when the doppler signal has high intensity, phases are relatively lower. The paper also formulates the size of speckles seen by the LDV in terms of the distance between LDV and the target surface, the wavelength of the LDV beam, and the spot size of the LDV beam on the surface (I mention this here because it will come later into play in another paper). Afterward, by using an experiment, the paper shows how low and high surface roughness affect the noise of LDV measurements, and then formulates the frequency spectrum of speckle noise. In this formulation, the root means square of the velocity noise and the standard deviation of the change of phases between 2 speckles was considered, unlike the previous study [5]. However, this formulation omits the change in speckle sizes with respect to distance and level of surface roughness. Next, the paper also shows (i) how
in-plane and out-of-plane LDV vibrations affect the measurements when the laser beam is not exactly incident on the target surface, as well as (ii) the formulations of the noise level of harmonic peaks of the noise spectrum which occurs when the LDV takes measurements from a rotating surface of LDV beam is scanned periodically on a surface (both of which causes periodic translations of the speckles in the LDV, leading to harmonic peaks in the frequency spectrum of speckle-noise).
[6] uses the autocorrelation function of the phase derivative of the demodulated signal formulated in [5] and the information presented in [4] (i.e., noise level decreases after a cut-off frequency) to calculate the frequency of the spectrum of speckle noise. Afterward, for the LDV measurements performed for remote-speech detection, the paper develops an impulsive noise filter since speckle noise in moving LDV measurements causes impulses in the recorded LDV measurements.
It should be noted that the frequency spectrum of the speckle noise obtained in the last 2 papers depends on the distance between LDV and the target surface by considering the spot size on the surface (which changes depending on the distance between LDV and the target surface). However, surface roughness, power of the laser, changing speckle size with respect to distance, the effect of other components of the LDV, and a combination of multiple laser beams in new generation lasers to reduce the noise, are omitted in the formulation of LDV speckle noise.
[7,8] use simulations to calculate the speckle noise which can incorporate surface roughness. The paper formulates the intensity and phase of the doppler signal considering the quadrature components of the Doppler signal. In the simulations, a matrix of speckles (which are divided into small sizes) was used. I will explain step by step what this study did/showed:
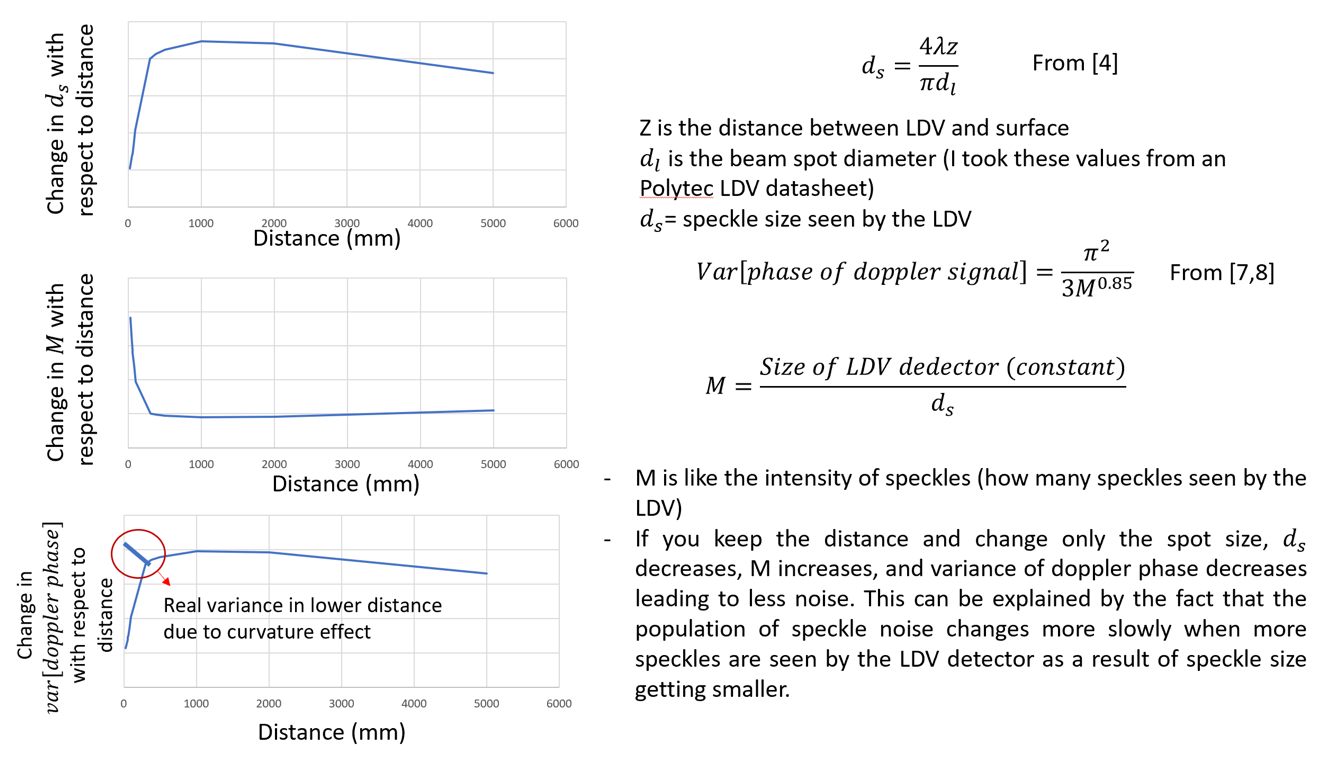
- Variation of phase changes are formulated in terms of the ratio of the detector size (which is constant) to the speckle size in the direction of the motion. According to this formulation, the variance of phases should decrease as the distance between LDV and surface increases, leading to less noise (as a result of more power in the LDV since LDV sees more speckles). (Note: I had to find the speckle size formulation in [4] to see how speckle sizes are changes with respect to distance, and also had to find how to spot size also changes with respect to distance (using the manual of an LDV) since the speckle sizes equation requires spot size). Basically, if more speckles are seen by the detector (i.e., low ratio of detector size to speckle diameter), less rapid speckle pattern changes, leading to less noise.
- However, in short, LDV-target distances, where the LDV power is high, speckle noise was lower, and this was explained as the curvature effect of the speckle map in such short distances. In the simulations, this effect was also incorporated.
- Simulation results were presented in terms of Doppler signal amplitude (which depends on the number of speckles captured by the detector, and their intensities too of course, in the LDV), and RMS speckle-noise magnitude. These two values were calculated for different ratios of detector size to speckle size in the direction of motion (which is a function of the distance between LDV and target). The results were compared with the measurements.
- Track and hold filter which holds the value of the signal at a level to prevent it to decrease below a certain value was also considered in the simulations. Note: Some commercial LDVs have such filters embedded in their controllers.
In the figure below, I combined the equations from different papers to understand really what’s going on for the phase of the doppler signal (though what is really going on with LDV noise with respect to different LDV-target distance may be more complicated than here presented. For example, what I observed that increasing the distance of LDV is always decreasing the noise in moving LDV measurements, but according to var[doppler phase] that I calculated using the equations, noise is not a gradually decreasing value):
- P. Castellini, M. Martarelli, E.P.Ã. Tomasini, Laser Doppler Vibrometry : Development of advanced solutions answering to technology ’ s needs, 20 (2006) 1265–1285. https://doi.org/10.1016/j.ymssp.2005.11.015.
- S.J. Rothberg, M.S. Allen, P. Castellini, D. Di Maio, J.J.J. Dirckx, D.J. Ewins, B.J. Halkon, P. Muyshondt, N. Paone, T. Ryan, H. Steger, E.P. Tomasini, S. Vanlanduit, J.F. Vignola, An international review of laser Doppler vibrometry : Making light work of vibration measurement, Opt. Lasers Eng. 99 (2017) 11–22. https://doi.org/10.1016/j.optlaseng.2016.10.023.
- M. Johansmann, Targeting the Limits of Laser Doppler Vibrometry, (2005) 1–12.
- A. Dräbenstedt, P. Gmbh, P. Platz, Quantification of Displacement and Velocity Noise in Vibrometer Measurements on transversely moving or rotating Surfaces, (n.d.).
- K.D. Ridley, E. Jakeman, FM demodulation in the presence of multiplicative and additive noise, Inverse Probl. 15 (1999) 989–1002. https://doi.org/10.1088/0266-5611/15/4/310.
- T. Lv, X. Han, S. Wu, Y. Li, The effect of speckles noise on the Laser Doppler Vibrometry for remote speech detection, Opt. Commun. 440 (2019) 117–125. https://doi.org/10.1016/j.optcom.2019.02.014.
- S.J. Rothberg, B.J. Halkon, Laser vibrometry meets laser speckle, Sixth Int. Conf. Vib. Meas. by Laser Tech. Adv. Appl. 5503 (2004) 280. https://doi.org/10.1117/12.579760.
- S. Rothberg, Numerical simulation of speckle noise in laser vibrometry, Appl. Opt. 45 (2006) 4523–4533. https://doi.org/10.1364/AO.45.004523.
Paper: Introducing speckle noise maps for laser vibrometery
Two test set-ups were established to quantify the speckle noise for periodic in-plane and tilt motions of the target surface for different surface roughness levels. Therefore, the study tried to minimize the vibrations of the test set-up in the direction of the incident laser beam.
For the test-set up of the in-plane measurements, two laser beams were used to try to align the incident laser beams exactly perpendicular to the surface, and one of them was used to measure the periodic in-plane motion. For the tilt motions, the laser beam was adjusted to shoot the exact center of the rotational axis. The Doppler signal presented showed that (i) artificial peaks in the recorded velocity signals occur usually when the doppler signal intensity is low and the doppler signal phase is very high, (ii) but such peaks can occur when the doppler signal intensity is still high if the doppler signal phase is high.
The study illustrated that the speckle noise increases proportional to the frequency of the surface motions but the phase level stays constant. However, because the rate of phase changes as the frequency of the surface motion changes, the speckle noise level changes accordingly.
The paper presented the speckle patterns seen by the LDVs considering different surface roughness and laser beam. It was shown that the speckle’s translate but do not evolve in tilt motions (except some evolution of speckles were observed for measurements obtained from a surface with retro-reflective tape). It was also shown that speckles evolve in in-plane motions. Therefore, the study showed that smaller laser beams provide less speckle noise when tilt motion occurs on the target surface since larger speckles are seen by LDV (actually speckle sizes are the same but they are relatively large since the laser beam is small) cause phase variations that happen over a greater time, thus reduce the speckle noise. For measurements from a surface with in-plane motions, a larger beam diameter produces less speckle noise. This is because, for a larger laser beam, the change in the population of scatters in the speckle noise is slower compared to the case of the smaller laser beam, hence resulting in less speckle noise. This also satisfies the formulation of speckle-noise presented above (however the previous paper calculating speckle noise level analytically could not include the effect of the ratio of speckle size to laser beam, and only considered the laser beam diameter in the analytic formulation of speckle-noise [because speckle size also changes with respect to distance and spot size]).
Speckle noise maps (mean level and standard deviations of noise obtained from different measurements) were presented by normalizing against angular and translational velocities at each harmonic peak in the frequency spectrum (i.e., harmonic peaks in the frequency spectrums are observed in cases where the speckle noise exhibits periodic patterns due to periodic surface motions) to enable to quantification of speckle noise at any vibrational frequency. The results obtained from the surface exhibiting tilt motion demonstrated high sensitivities to laser beam size and small sensitives to surface roughness levels. The results obtained from the surface exhibiting in-plane motions suffered from out-of-plane vibrations since the results obtained from the different surfaces were not consistent for lower harmonics. Therefore, such measurement suffered from out-of-plane vibrations which was not the case for measurements obtained from the surface exhibiting tilt motion.
Paper: Introducing speckle noise maps for laser vibrometery
This study is a continuation of the previous one. For the periodic tilt and transverse motions, the study suggested a method where two laser beams are used: one measuring the only out-of-plane vibrations by being incident on one segment of the surface having a mirror, and one measuring both out-of-plane vibrations and in-plane vibrations. Subtracting these two eliminated the out-of-plane vibrations. Then speckle noise maps (where noise is normalized with the velocity of the surface again) were presented. As 2 laser beams were used, it was possible to only obtained the out-of-plane vibrations and it was also demonstrated that out-of-plane vibrations were significant, showing the importance of eliminating them to obtain only the speckle noise. Speckle noise maps of the transverse periodic motions demonstrated that maximum speckle noise in the time domain in terms of artificial peaks occurred in the temporal vicinity of maximum surface velocity, and that surface roughness did not have a huge effect except for the surface with very minimum surface roughness and small laser spot beam diameter. For the radial and torsional motions of rotating shafts, the study suggested another method which is based on using two very closely located laser beams. The idea is that when the signals obtained using these 2 laser beams are subtracted, the correlated out-of-plane vibrations will be eliminated and when the subtracted signal is divided by the square root of 2, speckle noise is obtained. The problem with measurements obtained from rotating surfaces is the out-of-roughness. Using the second proposed method, the effect of out-of-roughness diminished as well in addition to the elimination of out-of-plane vibrations, but the effect of out-of-roughness was still obvious. Therefore, the study suggested using the noise level at higher-order harmonics to eliminate the effect of out-of-roughness. The study also showed the advantage of using a larger laser beam when the motion of the surface is translational, and of using a smaller laser beam when the motion of the surface is rotational.
Paper: Experimental investigation of the effect of speckle noise on continuous scan laser doppler vibrometer measurements
The paper first mentions about methods to obtain modal parameters from CSLDV measurements: (i) Fourier Series Expansion Method (based on sidebands) and (ii) Lifting Method (based on eliminating the time dependence in different measured points).
The paper also says that increasing the spot size decreases the speckle size (in line with equations presented before), and when the spot diameter size is large (many small speckles are observed by the detector), any small motion of laser beam will cause speckle noise since speckles will transition off, compared to the small spot diameter where a large spackle may not transition off. This is contradictory to what the previous papers say. But then, the paper says that defocusing the beam and making spot size larger may decrease the speckle noise (trying to say that larger spot diameter will produce less speckle noise as the previous papers say, however I think that: less focused laser beam may lead to a lower amplitude of the doppler signal, increasing noise, need to experiment this!)
Then, the paper does the experimental investigation of CSLDV speckle noise (periodic and non-periodic components at the frequency spectrum) by changing scan length, target to detector separation distance and sampling frequency. Following outcomes were observed:
- First, time domain plots of each cycle (in same plot) showed that the noise seems to be random with a periodically changing envelope, but close investigation showed that noise signal repeats itself to a significant extent each period.
- It was observed that amplitude envelope was caused by the variation in the surface velocity of the laser spot derived by the mirror driving signal (sin function). Even though speckle noise can be sensitive to small deviations from an exact periodic scan line, the frequency spectrums and time-domain responses contained a significant amount of periodicity.
- The noise amplitude, especially components near the fundamental scan frequency, is sensitive to the rate at which speckles transition through the detector. Mirror driving functions with time varying velocities seem to enhance the periodic component of noise, especially at the fundamental scan frequency.
- When the mirror was driven by a triangle function, a constant amplitude modulation was observed in the recorded time domain signals.
- For periodic speckle noise, noise vs max surface velocity curves (please see the paper for these figures) cluster together for a given target-detector separation, indicating that speckle noise is dependent on surface velocity and target-to-detector separation. For same scan length, and considering the same surface velocity ranges (as the target-detector distance increase, speed increases for same scan rate since more distance is covered at given time), target-detector distance separation changes the speckle noise: larger distance causes less noise (the paper says at the conclusion section that this may be due to increased signal amplitude at higher distance due to seeing more speckles, which is the same conclusion of previous papers saying that larger beam have more speckles, and hence increasing the doppler amplitude, but I think: it may be also due to low transition speed of higher density speckles when the laser beam is moving, and I think that these two are connected but the paper did not mention about this as a reason)
- Non-periodic components of noise obtained using Fourier Series Expansion Method showed similar results except longer scan lengths caused increased noise even at same speeds. In conclusion section of the paper, this was attributed due to fact that increased scan lengths number of speckle patterns observed in a given time interval.
- Non-periodic components of noise obtained using Lifting Method again showed similar results except that longer scan lengths caused increased noise even at same speeds. In addition, the noise didn’t change much with respect to speed, which was also different in previous last observation. Therefore, speed of laser beam seem to have not much effect on the noise levels for the Lifting Method, and the paper explains this by saying that the noise level at each spatial point would not change with respect to different scan frequency (which changes the speed of the laser beam). For full explanation, please see the paper.
- Increasing the sampling frequency increases the spatial resolution in scanning measurements when Lifting Method is used. but it also increases the noise as frequency range is increased, therefore, the paper discusses about finding an optimum sampling frequency.